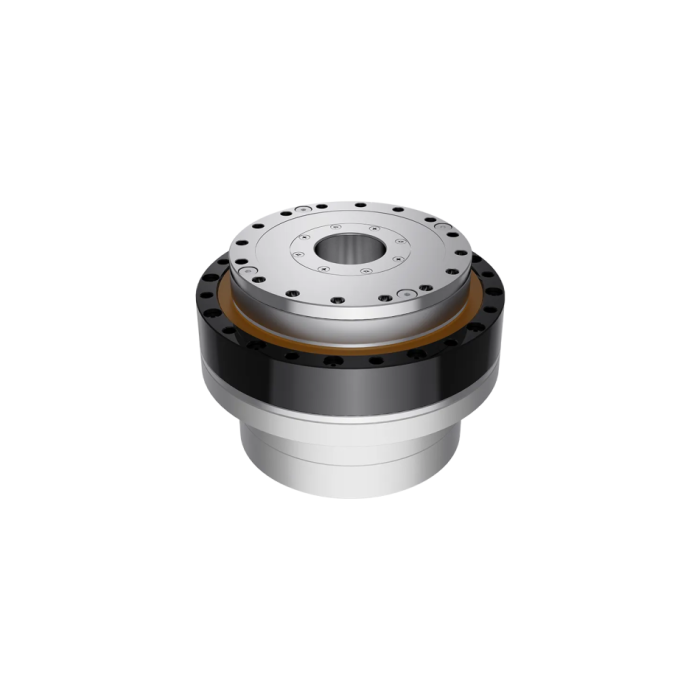
Ti5 Robotics 100-142 Lightweight Joint Module
В наличии
- БРЕНД:
- TI5 ROBOTICS
- МОДЕЛЬ:
- 100-142
- ORIGIN:
- Китай
- Warranty:
- 12 МЕСЯЦЕВ
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Ti5-Robotics-Joint-Module-100-142
Ti5 Robotics 100-142 Lightweight Joint Module
Ti5 Robotics 100-142 Lightweight Joint Module is a modular, integrated robotic joint actuator from the Ti5 Robotics lightweight joint module line, model 100-142. The family combines a compact housing, a hollow shaft for cable routing, and documented gear-ratio options, and it is offered in four joint versions that share a common electrical platform while differing in length, mass, inertia, and communication interface. This page describes the full 100-142 family as a single listing, with every documented variant covered in the narrative and specification table rather than as separate purchasable SKUs.
Background
A modular approach to robot joints
According to the manufacturer, the 100-142 is built around a modular, integrated, and lightweight design philosophy. Modularity is intended to make assembly flexible and maintenance straightforward: a joint can be mounted, serviced, or replaced as a self-contained unit instead of requiring work on individually matched motors, reducers, and encoders. The lightweight structure is aimed at improving mobility and energy efficiency in the machines that use it, while the highly integrated internal layout is intended to optimize space utilization and performance output in dense robot structures such as arms, legs, and torsos.
The 100-142 model family
The source documents four joint versions of the 100-142. Three of them carry full parameter tables: CRA-RI100-142-PRO-2-XXX, CRA-RI100-142-PRO-2-XXX-B, and CRA-RI100-142-PRO-2-XXX-2E-EC. A fourth version, CRA-RI100-142-PRO-2-XXX-B-2E-EC, is listed with a drawing reference but without published parameter values, so its specifications are not reproduced here. The "XXX" placeholder in each designation corresponds to the selected gear ratio. All documented versions are offered with five gear ratios — 51, 81, 101, 121, and 161 — and torque and speed figures change with the ratio, so no single torque or speed number should be read as universal for the family.
Technical Specifications
The following tables preserve the published configuration distinctions. Blank, malformed, or ambiguous source values are not confirmation of a capability; confirm the selected configuration during quotation.
CRA-RI100-142-PRO-2-XXX
| Gear Ratio | Peak Torque (N.m) | Max Allowable Torque At Average Load (N.m) | Rated Torque @ 2000RPM (N.m) | Peak Speed (RPM) | Rated Speed (With 1/2 Rated Torque) (RPM) | Gear Backlash (arcsec) |
| 51 | 267 | 133 | 94 | 55 | 44 | 20 |
| 81 | 376 | 206 | 146 | 37 | 29 | 20 |
| 101 | 411 | 267 | 169 | 29 | 22 | 10 |
| 121 | 436 | 267 | 169 | 24 | 18 | 10 |
| 161 | 459 | 267 | 169 | 18 | 12 | 10 |
| Rated Power(W) | Supply Voltage(V) | Max Continuous Current(A) | Rated Current(A) | Torque Constant (N.m/A) | Encoder Resolution (bit) | Communication Bus |
| 1000 | 24-48 | 16.9 | 15.8 | 0.175 | 16 | CAN |
| Hollow Shaft(mm) | Length(mm) | Mass(kg) | Inertia(g * c㎡) |
| 32 | 100.5±0.5 | 3.96 | 3910.2 |
CRA-RI100-142-PRO-2-XXX-B
| Gear Ratio | Peak Torque (N.m) | Max Allowable Torque At Average Load (N.m) | Rated Torque @ 2000RPM (N.m) | Peak Speed (RPM) | Rated Speed (With 1/2 Rated Torque) (RPM) | Gear Backlash (arcsec) |
| 51 | 267 | 133 | 94 | 55 | 44 | 20 |
| 81 | 376 | 206 | 146 | 37 | 29 | 20 |
| 101 | 411 | 267 | 169 | 29 | 22 | 10 |
| 121 | 436 | 267 | 169 | 24 | 18 | 10 |
| 161 | 459 | 267 | 169 | 18 | 12 | 10 |
| Rated Power(W) | Supply Voltage(V) | Max Continuous Current(A) | Rated Current(A) | Torque Constant (N.m/A) | Encoder Resolution (bit) | Communication Bus |
| 1000 | 24-48 | 16.9 | 15.8 | 0.175 | 16 | CAN |
| Hollow Shaft(mm) | Length(mm) | Mass(kg) | Inertia(g * c㎡) |
| 32 | 121.5±0.5 | 4.38 | 4744.7 |
CRA-RI100-142-PRO-2-XXX-2E-EC
| Gear Ratio | Peak Torque (N.m) | Max Allowable Torque At Average Load (N.m) | Rated Torque @ 2000RPM (N.m) | Peak Speed (RPM) | Rated Speed (With 1/2 Rated Torque) (RPM) | Gear Backlash (arcsec) |
| 51 | 267 | 133 | 94 | 55 | 44 | 20 |
| 81 | 376 | 206 | 146 | 37 | 29 | 20 |
| 101 | 411 | 267 | 169 | 29 | 22 | 10 |
| 121 | 436 | 267 | 169 | 24 | 18 | 10 |
| 161 | 459 | 267 | 169 | 18 | 12 | 10 |
| Rated Power(W) | Supply Voltage(V) | Max Continuous Current(A) | Rated Current(A) | Torque Constant (N.m/A) | Encoder Resolution (bit) | Communication Bus |
| 1000 | 24-48 | 16.9 | 15.8 | 0.175 | 16/18 | CAN/EtherCAT |
| Hollow Shaft(mm) | Length(mm) | Mass(kg) | Inertia(g * c㎡) |
| 32 | 103.5±0.5 | 3.97 | 5935.35 |
How do gear ratio and version choice change the 100-142?
Within each documented version, moving from the 51 ratio to the 161 ratio raises peak torque from 267 N·m to 459 N·m while peak speed falls from 55 RPM to 18 RPM, and backlash tightens from 20 arcsec to 10 arcsec at ratios of 101 and above. Between versions, the differences are physical and electrical rather than torque-related: the B version is longer (121.5 mm) and heavier (4.38 kg) than the base version, while the 2E-EC version adds a 16/18-bit encoder option and CAN/EtherCAT communication at 103.5 mm length and 3.97 kg, with higher reflected inertia. Selecting a 100-142 therefore means choosing both a version and a gear ratio against the torque, speed, precision, and bus requirements of the target joint.
Who is the Ti5 Robotics 100-142 Lightweight Joint Module for?
The 100-142 is aimed at robotics engineers and integrators building actuated structures that need high torque in a compact, serviceable package: humanoid robot developers, collaborative and industrial arm builders, research laboratories, and university teams. The manufacturer positions its joint module line for industrial production, scientific research and education, medical and rehabilitation platforms, and commercial scenarios. Buyers who need EtherCAT connectivity or higher encoder resolution should focus on the 2E-EC version, while CAN-based designs can use the base or B versions.
What is the Ti5 Robotics 100-142 Lightweight Joint Module used for?
- Actuating high-torque joints such as hips, shoulders, and torso axes in humanoid robot prototypes.
- Driving base and proximal joints of collaborative and research robot arms where peak torque up to 459 N·m is documented at the highest ratio.
- Scientific research and education platforms that benefit from a modular, replaceable joint unit.
- Medical and rehabilitation robotics development, as listed among the manufacturer's application areas.
- Commercial-scenario robots and automation mechanisms requiring integrated actuation with a 32 mm hollow shaft for cabling.
- EtherCAT-based control architectures, using the 2E-EC version's CAN/EtherCAT bus and 16/18-bit encoder options.
Pricing and Availability
Pricing for the 100-142 family depends on the version, gear ratio, and quantity selected, so it is quoted on request rather than published as a fixed figure. Because the four joint versions and five gear ratios form a configuration matrix, a short consultation on torque, speed, bus, and envelope requirements typically precedes a formal quotation. Availability and lead time are confirmed at the time of quotation.
Frequently Asked Questions
Which versions of the 100-142 are available?
Four joint versions are documented: CRA-RI100-142-PRO-2-XXX, the longer -B, the EtherCAT-capable -2E-EC, and the -B-2E-EC, for which the source publishes no parameter values.
What gear ratios can I choose?
Ratios of 51, 81, 101, 121, and 161 are documented, with peak torque rising and peak speed falling as the ratio increases.
What communication buses are supported?
The base and B versions use CAN; the 2E-EC version supports CAN/EtherCAT with a 16/18-bit encoder option.
How heavy is the module?
Documented masses are 3.96 kg (base), 4.38 kg (B), and 3.97 kg (2E-EC); the B-2E-EC mass is not published.
What is the supply voltage and rated power?
All documented versions operate from 24–48 V with 1000 W rated power, 15.8 A rated current, and 16.9 A maximum continuous current.
Does it have a hollow shaft?
Yes. All documented versions include a 32 mm hollow shaft for routing cables and lines through the joint axis.
Where can I buy the Ti5 Robotics 100-142 Lightweight Joint Module and what does it cost?
It is available through this listing on a request-for-quote basis. Submit your version, gear ratio, and quantity requirements to receive current pricing and lead time.
Summary
The Ti5 Robotics 100-142 Lightweight Joint Module is a modular, integrated joint actuator family offered in four versions and five gear ratios, pairing a shared 1000 W, 24–48 V electrical platform with version-specific length, mass, inertia, and bus options, and documented peak torque from 267 to 459 N·m depending on ratio. For specifying, comparing, and requesting a quotation on the right configuration, this page is the starting point.