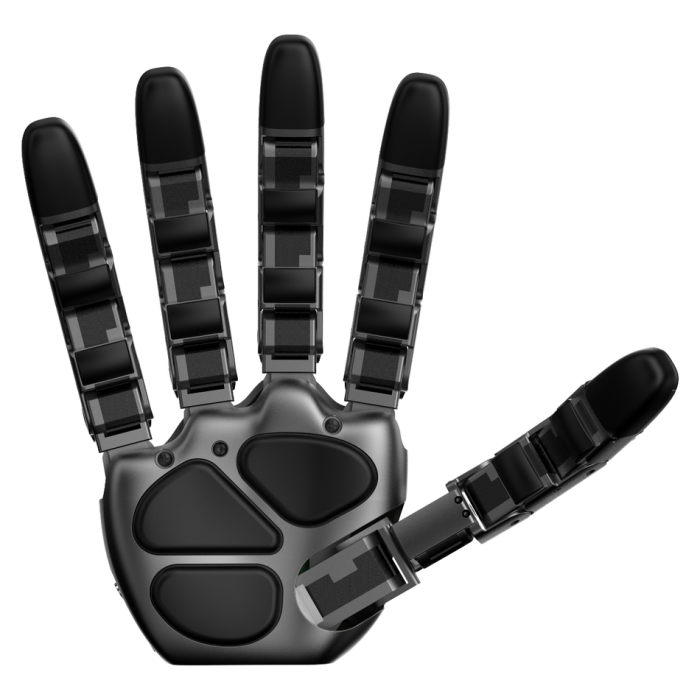
Wonik Robotics Allegro Hand V6 F
In stock
- STÄMPLA:
- Wonik Robotics
- MODELL:
- Allegro Hand V6 F
- DEL #:
- Allegro Hand V6 F
- Warranty:
- 12 MÅNADER
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Wonik-Allegro-Hand-V6-F
Wonik Robotics Allegro Hand V6 F
Overview
The Wonik Robotics Allegro Hand V6 F is a five-fingered robotic hand that combines pressure sensing across key contact areas with precise control, intended for integration across a wide range of robotic systems. Pressure sensors at key contact areas provide contact detection during manipulation, alongside versatile control modes and Modbus connectivity. The configuration is four fingers plus one thumb, with twenty active degrees of freedom arranged as four per finger.
The V6 F supports current and position commands and includes a High-Force Mode intended for tasks that require stronger, more secure grasping, while Modbus communication supports flexible system integration.
Design and Construction
The design is described as shaped by human anatomy. The fingers follow the enveloping configuration of the human hand, naturally distributing contact forces across varied object shapes and sizes. The palm uses a three-dimensional, contoured surface rather than a flat mechanical plane, stated to increase contact area and improve grasp stability.
The full aluminum body is stated to deliver the rigidity, precision, and durability needed for sustained use, with organic curves inspired by human skeletal and muscular forms. Integrated heatsinks on the upper fingers manage heat generated during high-load operation. The complete hand weighs 1,150 g.
Fingertip Visual Feedback
Each fingertip carries a visual indicator that glows directly at the fingertip, making grasping status immediately visible. The indicator maps colors to pressure ranges, from blue at or below 1050 hPa through green and olive to red at or above 1170 hPa.
Sensing
The V6 F provides full-hand sensing. Pressure sensors are placed on key contact areas, including the fingertips, finger joints, and palm, to detect various types of contact during grasping and manipulation. The stated pressure operating range is 260 to 1260 hPa (standard atmospheric pressure is 1,013.25 hPa), with an accuracy of 1 kPa. These values describe the sensors' operating range and accuracy and should not be read as a statement of grasp force or any guaranteed interaction behavior.
Verified Specifications
| Specification | Value |
|---|---|
| Number of fingers | 4 fingers + 1 thumb = 5 |
| Degrees of freedom | 5 fingers x 4 = 20 (active) |
| Actuation type | DC motor |
| Gear ratio | 288.35:1 |
| Stall torque | 0.92 Nm |
| Nominal torque | 0.23 Nm |
| Payload | Max. 15 kg |
| Weight | 1,150 g |
| Joint resolution | 0.088 deg |
| Communication interface | RS-485, Ethernet |
| Protocol | Modbus (RTU, TCP), RS-485 custom |
| Power requirement | 24.0 V / 5.0 A / 120 W |
| Tactile sensor | Pressure sensor |
| Pressure operating range | 260 to 1260 hPa |
| Pressure accuracy | 1 kPa |
| Temperature operating range | 0 to 60 C |
| Fingertip color indicator | Blue: at or below 1050 hPa; Green: 1050 to 1130 hPa; Olive: 1130 to 1170 hPa; Red: at or above 1170 hPa |
The maximum 15 kg payload is the manufacturer-published value and should be interpreted in the context of the task, grasp configuration, and object geometry involved.
Control Modes and Communication
The V6 F supports multiple control modes:
- Current control provides direct torque-level actuation for fine, force-sensitive manipulation.
- Position control provides precise joint-angle positioning for repeatable, predictable motion, with a joint resolution of 0.088 degrees.
- Stiffness control allows adjustable joint stiffness for firm holds or impact-absorbing control behavior.
A High-Force Mode is also available for tasks that require stronger, more secure grasping. For communication, the V6 F provides RS-485 and Ethernet interfaces and supports Modbus RTU and TCP as well as an RS-485 custom protocol, enabling integration with robotic and automation systems used in industrial and manufacturing environments.
Compensation Algorithms
Friction and temperature compensation algorithms minimize potential control errors caused by friction and temperature variations, enabling stable and precise hand control across diverse operating environments.
User Interface and Monitoring
The V6 F is accompanied by interface and monitoring tools. Real-time hand status monitoring visualizes hand motion and pressure, a pose and sequence manager saves, loads, and repeats hand poses, and time-series monitoring presents trends in joint position, motor current, temperature, and sensor data.
Published system requirements for this software environment are an Intel Core i3-8109U CPU or higher, at least 2 GB of RAM and 2 GB of storage, OpenGL 3.0 graphics with hardware acceleration and at least 64 Mb of video RAM, and Ubuntu 22.04 LTS or 24.04 LTS. ROS2 is listed as additional software.
Research and Application Context
The manufacturer presents the V6 F for manipulation and integration with robotic and industrial automation systems. Twenty active degrees of freedom, torque-level current control, and distributed pressure sensing make both motion and contact information available to control software, while the monitoring tools provide the time-series data such studies typically require.
Integration Considerations
Prospective users should verify several points before planning an integration:
- Check that the host controller supports Modbus RTU over RS-485, Modbus TCP over Ethernet, or the RS-485 custom protocol.
- Confirm that the power supply can deliver 24.0 V at 5.0 A, the stated 120 W requirement.
- Review whether the operating environment stays within the stated 0 to 60 degrees Celsius temperature range.
- Verify that the host computer for the monitoring tools meets the published system requirements, including Ubuntu 22.04 LTS or 24.04 LTS.
- Evaluate whether the 1,150 g hand weight and the maximum 15 kg payload specification fit the mounting platform and the objects to be handled.
- Assess which control mode matches the task and whether High-Force Mode is needed for the grasps involved.
Frequently Asked Questions
How many fingers and degrees of freedom does the Allegro Hand V6 F have?
The Allegro Hand V6 F has five fingers, configured as four fingers plus one thumb, and provides twenty active degrees of freedom, arranged as four degrees of freedom per finger.
What kind of tactile sensing does the V6 F use?
The V6 F uses pressure sensors at the fingertips, finger joints, and palm, with an operating range of 260 to 1260 hPa and a stated accuracy of 1 kPa, intended to detect contact during grasping and manipulation.
Which control modes are supported?
The hand supports current control for torque-level actuation, position control for precise joint-angle positioning, and stiffness control for adjustable joint stiffness, plus a High-Force Mode for tasks that require stronger, more secure grasping.
What communication interfaces and protocols does the hand provide?
The V6 F provides RS-485 and Ethernet interfaces. Supported protocols are Modbus in RTU and TCP variants, along with an RS-485 custom protocol, positioned for integration with industrial robotic and automation systems.
What do the fingertip indicator colors mean?
Each fingertip indicator reflects measured pressure: blue at or below 1050 hPa, green for 1050 to 1130 hPa, olive for 1130 to 1170 hPa, and red at or above 1170 hPa, making grasping status visible at a glance.
What are the power and host computer requirements?
The hand requires 24.0 V at 5.0 A (120 W). For the monitoring tools, the published requirements include an Intel Core i3-8109U CPU or higher, 2 GB of RAM and storage, OpenGL 3.0 graphics, Ubuntu 22.04 LTS or 24.04 LTS, and ROS2.
Summary
The Wonik Robotics Allegro Hand V6 F is a five-fingered, twenty-degree-of-freedom robotic hand built around DC motor actuation, an anatomically inspired aluminum structure with integrated heatsinks, and full-hand pressure sensing at the fingertips, joints, and palm. It combines current, position, and stiffness control modes with a High-Force Mode, friction and temperature compensation algorithms, and RS-485 and Ethernet connectivity using Modbus RTU and TCP plus an RS-485 custom protocol. Fingertip color indicators and monitoring tools provide visibility into hand state, pose management, and time-series data. The specifications and integration points above summarize the manufacturer's published information for this model.
Request a quotation to confirm configuration, pricing and availability. Catalog stock status is not confirmation of physical inventory or immediate shipment.