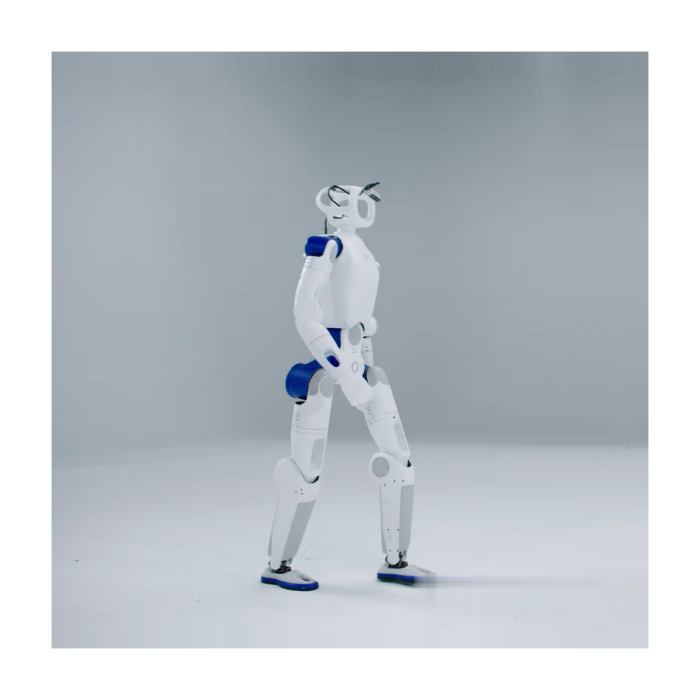
RoboParty ROBOTO 01 (RP1 Pro)
In stock
- MARKË:
- RoboParty
- MODEL:
- RP1 Pro
- ORIGIN:
- Kinë
- Warranty:
- 12 MUAJ
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- RoboParty-RP1-Pro
RoboParty ROBOTO 01 (RP1 Pro)
The RoboParty RP1 Pro is a humanoid robot development platform in the manufacturer’s ROBOTO 01 family. It is intended for researchers and independent developers who need access to both hardware and software rather than a closed demonstration system. RoboParty publishes separate RP1 and RP1 Pro specifications, so the selected version matters when assessing articulation, computing hardware, hands and interaction equipment.
Watch RoboParty’s official RP1 family launch video. This family overview does not establish Pro-specific equipment.
Configuration and Mechanical Design
The RP1 Pro has 30 active degrees of freedom, including two at the head, seven per arm, two at the waist and six per leg. Its listed physical mass is approximately 41 kg with end effectors and battery. The standard interaction head includes a monocular RGB camera, and the standard end effectors are described as 6-DOF dexterous hands. The computing table lists an RK3588 plus A733 base arrangement and an Orin NX with 16 GB for development computing. The published 24-DOF and 30-DOF body totals remain unchanged when discussing optional end effectors; hand degrees of freedom are not added to those totals.
Both variants stand 1.35 m tall. The published standing dimensions are 1350 × 450 × 200 mm in height, body width and body depth respectively. Thigh length is 250 mm, calf length is 300 mm, and total single-arm length is 550 mm. These measurements describe the robot body, not its transport packaging or the clearance needed for a moving experiment. The manufacturer identifies AL6061/7075 aluminium alloys, engineering plastics and special rubber as body materials.
Motion and Actuation
RoboParty lists a maximum running-speed figure of ≤4 m/s, a 30° climbing capability and a maximum step-crossing height of 50 mm. The obstacle-avoidance minimum-size entry is also 50 mm. These are manufacturer specifications rather than a promise of identical results on every surface. The page explicitly states that motion performance varies with load, terrain, battery condition and software configuration.
The payload entry is 3 kg, but the table does not define how that load is distributed between arms or hands. It should not be presented as a per-hand lifting rating. Four in-house joint-module designs use a two-stage planetary, inner-rotor structure. The 160 N·m peak-torque figure is specifically associated with the 100 mm outer-diameter module model; it is not a continuous-torque rating for every joint.
Battery and Laboratory Operation
The published battery capacity is 10 Ah, with a stated runtime of three hours and charging time of 1.5 hours. A large-and-small dual-battery arrangement supports battery replacement without shutting down. USB-C and magnetic charging are listed, along with support for operation while charging. The exact charging-power rating should be confirmed for the supplied configuration. Actual runtime remains dependent on the task and configuration rather than being a fixed duration under every research workload.
The operating-temperature range is -10 to 40 °C. Rounded soft-rubber handles and rear battery removal are identified as handling and maintenance features. The manufacturer also describes fully enclosed joints intended to reduce pinch exposure, remote and wearable emergency stops, and three-channel emergency-stop redundancy. These design features do not establish a particular safety certification or remove the need for a site-specific operating procedure.
Optional Heads, Hands and Sensors
The head architecture supports motion-control, interaction, perception and data-collection configurations selected according to the project. An Intel D435i depth camera is optional. The perception-head configuration combines that depth camera with 3D LiDAR, while the data-collection head uses a binocular RGB camera. Those sensor packages must not be treated as equipment supplied with every robot. A high-precision six-axis IMU is listed for both base variants.
The wrist architecture accommodates dummy hands, dexterous hands and grippers. Optional dexterous-hand configurations are listed as 6 DOF or 22 DOF; the selected hand and its inclusion should be confirmed separately. End-effector internal wiring is specified at 24 V, with provision for an adapter board. Reserved interfaces and structural mounting holes provide expansion points, but the page does not establish universal compatibility with any arbitrary accessory.
Connectivity and Open Development
Both versions list Wi-Fi 6, Bluetooth 5.2 and 4G, together with two USB Type-A ports, two USB Type-C ports and two RJ45 ports. The Pro interaction equipment includes a speaker, microphone and screen, with remote, app and voice control listed.
The open-development material covers module and body drawings, bills of materials, interfaces, PCB information and 3D models. Software resources include motor drivers, gait algorithms, perception and decision models, ROS 2 middleware, an SDK, simulation environments and training code. This scope makes the platform relevant to projects connecting mechanical changes with control and learning experiments. The specific repository release and resource completeness should be checked before planning an implementation.
Applications and Procurement
The platform is positioned for humanoid locomotion, whole-body control and development work that benefits from access to the underlying design. Perception or interaction experiments depend on the chosen head and computing configuration, not simply on the family name. Purchase discussions should identify the exact version, supplied hands, sensors, computing modules, battery equipment and documentation revision. This draft does not establish a selling price, stock position, shipping mass or delivery commitment.
Frequently Asked Questions
What is the RoboParty RP1 Pro?
It is the RP1 Pro variant of RoboParty’s open humanoid development platform, with 30 active degrees of freedom and published hardware and software development resources.
How does the RP1 Pro support development?
It combines articulated robot hardware with access to structural, electronic, control, simulation and training resources. Researchers must select and validate the configuration needed for their own experiments.
Are depth cameras and LiDAR included?
Not by default across the family. The Intel D435i is optional, and the combined depth-camera and LiDAR arrangement belongs to the selected perception-head configuration.
What are the main practical benefits?
The documented open hardware and software make it possible to examine multiple layers of the platform. Hot-swappable batteries and configurable heads provide additional flexibility for laboratory workflows.
Where can I buy the RP1 Pro?
Use the manufacturer’s product page to start a configuration and quotation enquiry. Confirm the supplied equipment, commercial terms and current availability rather than assuming that every shown option is included.
Summary
The RP1 Pro is a configurable research humanoid whose value lies in its documented development access and clearly differentiated variant equipment. Evaluation should use its own specification column and distinguish standard hardware from optional sensing and manipulation packages.