Ti5 Robotics T170D Humanoid Robot
In stock
- MÁRKA:
- TI5 ROBOTICS
- MODELL:
- T170D
- ORIGIN:
- Kína
- Warranty:
- 12 HÓNAP
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Ti5-Robotics-T170D
Ti5 Robotics T170D Humanoid Robot
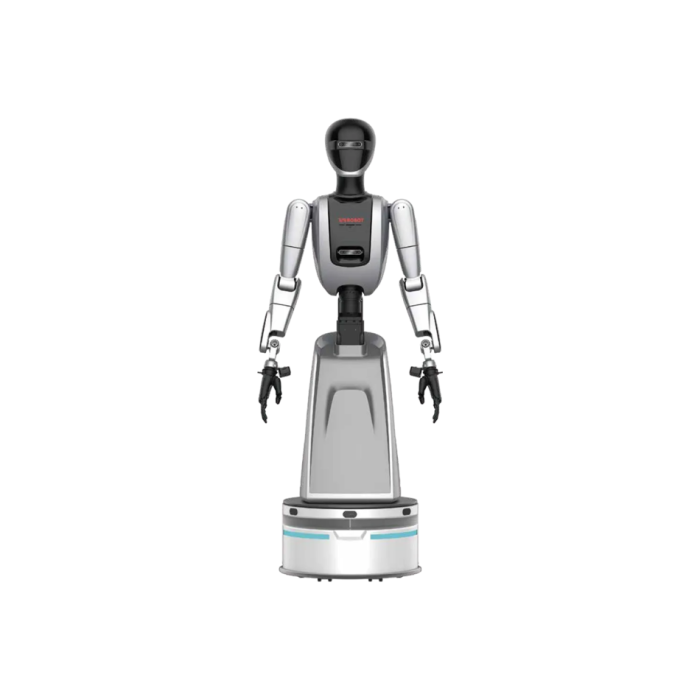
Ti5 Robotics T170D Humanoid Robot is a wheeled, dual-arm humanoid platform offered in two documented configurations: the Standard Model 170D and a Flagship Model. Both builds stand 1.5 m tall with an additional 16 cm of lifting height, weigh 96 kg gross, and span 1.35 m across the arms. With 21 active degrees of freedom, harmonic-reducer joint actuators, dexterous six-DOF hands, and an onboard Jetson compute platform, the T170D is positioned as an integration-ready base for manipulation research, development, and service-robotics programs rather than a fixed-function appliance.
Background
The T170D comes from a manufacturer that specializes in the research, development, and manufacturing of intelligent robotic products and core components for humanoid robots, including lightweight joint modules, bionic hands, and collaborative robot arms. The T170D applies that component portfolio to a complete mobile humanoid.
A component maker's complete platform
Because the same company produces joint actuator modules, harmonic reducers pairings, and dexterous hands, the T170D is built around in-house actuation. Joints use CAN and EtherCAT (EC) actuator interfaces with harmonic reducers and 18-bit joint encoders, while the hands communicate over a 485 bus. This vertical approach matters to integrators: the arm, hand, and chassis subsystems are documented under one parameter table, and a dual-arm API is supplied as the software entry point. The product sits in the vendor's humanoid robot actuator line, but it is a complete robot platform, not a standalone motor or actuator component.
Two configurations, one family
The source documentation lists the Standard Model 170D and the Flagship Model side by side. Most dimensions and joint characteristics are shared, and the meaningful differences concentrate in the hands, sensing, and compute. The Standard build pairs the TH-RH-1-L/R dexterous hand (0.5 kg hand load) with a Jetson Orin Nano 8G controller and lists no joint force sensor. The Flagship build upgrades to a high-precision dexterous hand rated for a 2–3 kg hand load, adds two six-dimensional force sensors, and moves compute to a Jetson AGX Orin 64G Developer Kit on an ARM platform. Buyers should treat these as distinct configurations of one listing rather than interchangeable specs.
Technical Specifications
The following tables preserve the published configuration distinctions. Blank, malformed, or ambiguous source values are not confirmation of a capability; confirm the selected configuration during quotation.
Ti5 Robotics T170D Humanoid Robot
| Model | T170D Standard Model | 170D Flagship Model |
| Total height | 1.5m + 16cm lifting height | 1.5m + 16cm lifting height |
| gross weight | 96kg | 96kg |
| Arm span | 1.35m | 1.35m |
| Total number of active degrees of freedom | 21 | 21 |
| Single-arm load | 2-3KG | 2-3KG |
| End-effector repeatability | ≤0.3mm | ≤0.3mm |
| Dexterity of hand active freedom | 6 | 6 |
| Hand load | 0.5KG | 2-3KG |
| Dexterous Hand Model | TH-RH-1-L/R | High-precision dexterity hand |
| Joint actuator type | CAN and EC | CAN and EC |
| Joint reducer type | harmonic | harmonic |
| Joint encoder resolution | 18bit | 18bit |
| Joint sensor type | / | Six-dimensional force *2 |
| chassis | High-performance wheels | High-performance wheels |
| Chassis Mobility | maximum navigation speed1.5m/s | maximum navigation speed1.5m/s |
| Number and type of input/output ports | USBEthernet port, charging porttype-c | USBEthernet port, charging porttype-c |
| Software Algorithm | Dual-arm API | Dual-arm API |
| Material | Structure: Aluminum alloy, etc. Appearance: ABS, etc. | Structure: Aluminum alloy, etc. Appearance: ABS, etc. |
| Visual perception | Head: Intel RealSense D435*1; Wrist: Intel RealSense D405*2 | Head: Intel RealSense D435*1 Wrist: Intel RealSense D405*2 |
| Control and computing power | Jeston OrinNano 8G*1 | Jeston AGXOrin 64G Developer Kit ARM Platform |
| Communication Protocol | Joint CAN and EC, hand485 | Joint CAN and EC, hand 485 |
How do the Standard and Flagship configurations differ?
The chassis, arms, cameras, and frame are effectively identical across both builds. The purchasing decision therefore comes down to three axes. First, manipulation payload at the hand: 0.5 kg on the Standard's TH-RH-1-L/R hands versus 2–3 kg on the Flagship's high-precision hands. Second, force sensing: only the Flagship lists two six-dimensional force sensors, which is relevant for contact-rich manipulation and force-controlled tasks. Third, onboard compute: the Jetson Orin Nano 8G suits lighter perception workloads, while the AGX Orin 64G Developer Kit provides substantially more memory and processing headroom for running larger perception and planning stacks on the robot itself. Teams planning heavy onboard AI inference or force-feedback research will generally gravitate to the Flagship; teams offloading compute to workstations may find the Standard sufficient.
Who is the Ti5 Robotics T170D Humanoid Robot for?
The T170D targets robotics research groups, university labs, and commercial R&D teams working on dual-arm mobile manipulation. The documented dual-arm API, standard interfaces (USB, Ethernet, Type-C, CAN/EC, 485), and Intel RealSense head and wrist cameras make it suitable for developers who intend to write and deploy their own perception and manipulation software. The manufacturer lists industrial production, scientific research and education, medical and rehabilitation, and commercial scenarios as its application areas, and the wheeled chassis with 1.5 m/s navigation speed suits structured indoor floors rather than rough terrain.
What is the Ti5 Robotics T170D Humanoid Robot used for?
- Dual-arm manipulation research, using the 21-DOF body, dual-arm API, and ≤0.3 mm end-effector repeatability.
- Dexterous grasping development with the six-DOF hands, including heavier-object handling on the Flagship's 2–3 kg hand load.
- Vision-based perception work using the head-mounted RealSense D435 and two wrist-mounted D405 cameras.
- Force-controlled and contact-rich tasks on the Flagship configuration, which carries two six-dimensional force sensors.
- Scientific research and education programs, where the open interfaces and documented parameters support coursework and experimentation.
- Prototyping of commercial and industrial service tasks on indoor floors, within the platform's 2–3 kg single-arm load and wheeled mobility.
Pricing and Availability
Pricing for platforms in this class depends on the configuration selected — Standard versus Flagship, hand options, and any accompanying development support — so the T170D is sold on a quotation basis. Availability and lead times are confirmed at the time of inquiry. To receive current pricing for either configuration, submit a quote request with your intended use case and preferred build.
Frequently Asked Questions
What degrees of freedom does the T170D offer?
Both configurations list 21 total active degrees of freedom on the body, plus six active degrees of freedom in each dexterous hand.
How much can the T170D lift?
Each arm is rated for a 2–3 kg single-arm load. Hand load differs by configuration: 0.5 kg on the Standard Model 170D and 2–3 kg on the Flagship Model.
Is the T170D a walking (legged) robot?
No. The documented chassis uses high-performance wheels with a maximum navigation speed of 1.5 m/s, plus a 16 cm lifting mechanism that extends working height above the 1.5 m frame.
What computing hardware is onboard?
The Standard configuration carries one Jetson Orin Nano 8G; the Flagship configuration carries a Jetson AGX Orin 64G Developer Kit on an ARM platform.
What sensors are included?
Both builds include one Intel RealSense D435 head camera and two Intel RealSense D405 wrist cameras. The Flagship additionally lists two six-dimensional force sensors; the Standard lists no joint force sensor.
How do developers program the T170D?
The platform ships with a dual-arm API. Joints communicate over CAN and EtherCAT, hands over a 485 bus, and external connectivity includes USB, Ethernet, and Type-C ports alongside a charging port.
Where can I buy the Ti5 Robotics T170D Humanoid Robot and what does it cost?
The T170D is available through this listing on a request-for-quote basis. Because final cost depends on the configuration and options chosen, submit an inquiry specifying Standard or Flagship to receive an itemized quotation and current lead time.
Summary
The Ti5 Robotics T170D is a 1.5 m, 96 kg wheeled humanoid with 21 degrees of freedom, dexterous six-DOF hands, RealSense vision, and a dual-arm API, offered in Standard and Flagship configurations that differ in hand payload, force sensing, and onboard compute. For teams evaluating a dual-arm mobile manipulation platform, this page is the starting point.