Ti5 Robotics 60-80 Lightweight Joint Module
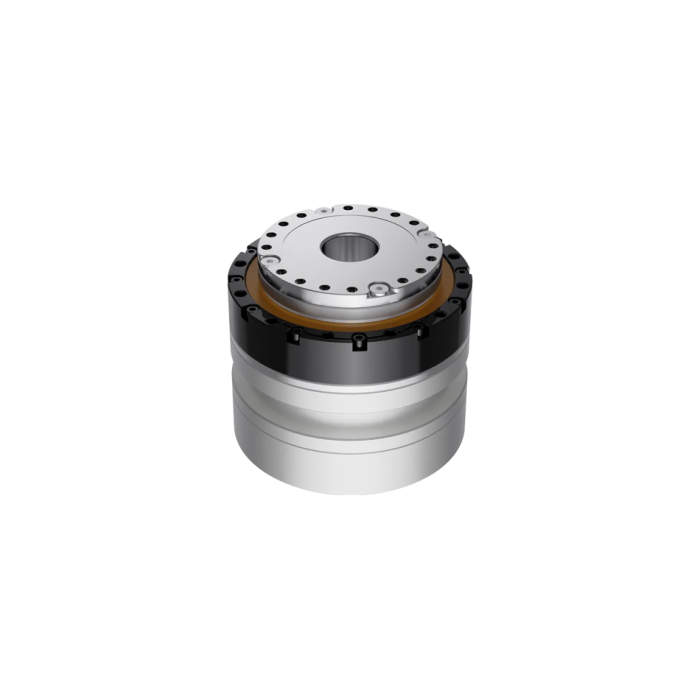
In stock
- MARCA:
- TI5 ROBOTICS
- MODELLO:
- 60-80
- ORIGIN:
- Cina
- Warranty:
- 12 MESI
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Ti5-Robotics-Joint-Module-60-80
Ti5 Robotics 60-80 Lightweight Joint Module
Ti5 Robotics 60-80 Lightweight Joint Module is an integrated rotary actuator in the Ti5 lightweight joint module line, combining a frameless motor, precision gear reducer, encoder, and drive electronics in a single compact housing. The model 60-80 family is offered in four joint versions — CRA-RI60-80-PRO-2-XXX, CRA-RI60-80-PRO-2-XXX-B, CRA-RI60-80-PRO-2-XXX-2E-EC, and CRA-RI60-80-PRO-2-XXX-B-2E-EC — each available with four gear ratios (51, 81, 101, and 121). The module targets humanoid robots, collaborative robot arms, and other intelligent equipment where mass, volume, and integration effort must be kept low.
Background
A modular, integrated actuator concept
Ti5 Robotics positions the 60-80 as a modular, integrated, and lightweight design. The actuator concentrates motor, reduction stage, feedback, and communication electronics into one unit, so a robot builder mounts a complete joint rather than assembling discrete components. According to the manufacturer, this modularity supports flexible assembly and easier maintenance, while the highly integrated layout optimizes space utilization and performance output. A central hollow shaft of 18 mm allows cabling to pass through the joint axis, which simplifies harness routing in serial-link arms and humanoid limbs.
Where the 60-80 sits in the Ti5 range
Ti5 Robotics manufactures a family of lightweight joint modules in multiple frame sizes, alongside intelligent bionic hands, collaborative robot arms, and humanoid robot actuators. The 60-80 is a mid-compact member of that range: documented versions weigh roughly 1.03 to 1.2 kg with body lengths of 72.5 mm or 91.5 mm, deliver up to 66 N·m peak torque depending on gear ratio, and run from a 24–48 V supply at 300 W rated power. The manufacturer cites application fields including industrial production, scientific research and education, medical and rehabilitation robotics, and commercial scenarios.
Technical Specifications
The following tables preserve the published configuration distinctions. Blank, malformed, or ambiguous source values are not confirmation of a capability; confirm the selected configuration during quotation.
CRA-RI60-80-PRO-2-XXX
| Gear Ratio | Peak Torque (N.m) | Max Allowable Torque At Average Load (N.m) | Rated Torque @ 2000RPM (N.m) | Peak Speed (RPM) | Rated Speed (With 1/2 Rated Torque) (RPM) | Gear Backlash (arcsec) |
| 51 | 42 | 32 | 19.8 | 82 | 68 | 20 |
| 81 | 53 | 33 | 27.5 | 51 | 43 | 20 |
| 101 | 66 | 49 | 30 | 41 | 34 | 10 |
| 121 | 66 | 49 | 30 | 32 | 24 | 10 |
| Rated Power(W) | Supply Voltage(V) | Max Continuous Current(A) | Rated Current(A) | Torque Constant (N.m/A) | Encoder Resolution (bit) | Communication Bus |
| 300 | 24-48 | 6.7 | 5 | 0.096 | 16 | CAN |
| Hollow Shaft(mm) | Length(mm) | Mass(kg) | Inertia(g * c㎡) |
| 18 | 72.5±0.5 | 1.03 | 394.8 |
CRA-RI60-80-PRO-2-XXX-B
| Gear Ratio | Peak Torque (N.m) | Max Allowable Torque At Average Load (N.m) | Rated Torque @ 2000RPM (N.m) | Peak Speed (RPM) | Rated Speed (With 1/2 Rated Torque) (RPM) | Gear Backlash (arcsec) |
| 51 | 42 | 32 | 19.8 | 82 | 68 | 20 |
| 81 | 53 | 33 | 27.5 | 51 | 43 | 20 |
| 101 | 66 | 49 | 30 | 41 | 34 | 10 |
| 121 | 66 | 49 | 30 | 32 | 24 | 10 |
| Rated Power(W) | Supply Voltage(V) | Max Continuous Current(A) | Rated Current(A) | Torque Constant (N.m/A) | Encoder Resolution (bit) | Communication Bus |
| 300 | 24-48 | 6.7 | 5 | 0.096 | 16 | CAN |
| Hollow Shaft(mm) | Length(mm) | Mass(kg) | Inertia(g * c㎡) |
| 18 | 91.5±0.5 | 1.2 | 492 |
CRA-RI60-80-PRO-2-XXX-2E-EC
| Gear Ratio | Peak Torque (N.m) | Max Allowable Torque At Average Load (N.m) | Rated Torque @ 2000RPM (N.m) | Peak Speed (RPM) | Rated Speed (With 1/2 Rated Torque) (RPM) | Gear Backlash (arcsec) |
| 51 | 42 | 32 | 19.8 | 82 | 68 | 20 |
| 81 | 53 | 33 | 27.5 | 51 | 43 | 20 |
| 101 | 66 | 49 | 30 | 41 | 34 | 10 |
| 121 | 66 | 49 | 30 | 32 | 24 | 10 |
| Rated Power(W) | Supply Voltage(V) | Max Continuous Current(A) | Rated Current(A) | Torque Constant (N.m/A) | Encoder Resolution (bit) | Communication Bus |
| 300 | 24-48 | 6.7 | 5 | 0.096 | 16/18 | CAN/EtherCAT |
| Hollow Shaft(mm) | Length(mm) | Mass(kg) | Inertia(g * c㎡) |
| 18 | 72.5±0.5 | 1.04 | 479.96 |
How do the four 60-80 joint versions differ?
The core motor and gearing performance is published identically across the documented versions; the differences lie in housing length, mass, encoder configuration, and fieldbus. The base CRA-RI60-80-PRO-2-XXX is the shortest and lightest, communicating over CAN with a 16-bit encoder. The -B version extends the body to 91.5 mm and raises mass to 1.2 kg; the source does not state the functional purpose of the longer housing, so buyers should confirm it with the manufacturer. The -2E-EC version keeps the short 72.5 mm body but adds a 16/18-bit encoder specification and CAN/EtherCAT connectivity, suited to synchronized multi-axis control. The -B-2E-EC version combines the two suffixes in its designation, but no parameter values are published for it in the source, so its data should be requested directly. Within every documented version, choosing a gear ratio trades speed for torque: ratio 51 reaches 82 RPM peak with 42 N·m peak torque, while ratios 101 and 121 deliver 66 N·m peak torque with tighter 10 arcsec backlash at lower speeds.
Who is the Ti5 Robotics 60-80 Lightweight Joint Module for?
This module is intended for robotics engineers, OEM machine builders, research laboratories, and system integrators who design humanoid robots, collaborative arms, or custom motion systems and prefer a ready-to-integrate joint over an in-house actuator build. It suits teams that need a documented torque-speed envelope, a hollow shaft for internal cabling, and a choice between CAN and EtherCAT control architectures. Procurement teams standardizing on a single joint family across several axes also benefit from the four-ratio, four-version structure.
What is the Ti5 Robotics 60-80 Lightweight Joint Module used for?
- Joint actuation in humanoid robot limbs, where low mass and integrated electronics reduce moving weight.
- Axes of collaborative robot arms, using different gear ratios for proximal and distal joints.
- Scientific research and education platforms that require a documented, repeatable actuator.
- Industrial production equipment needing compact rotary motion with low backlash.
- Medical and rehabilitation robotics development, an application field cited by the manufacturer.
- Commercial-scenario service robots and prototypes where EtherCAT or CAN integration is required.
Pricing and Availability
Pricing for the 60-80 family depends on the selected version, gear ratio, and order quantity, and is provided on a quotation basis. Contact our sales team with your target version (base, -B, -2E-EC, or -B-2E-EC), gear ratio, and axis count to receive a current quotation and lead-time estimate. Volume and multi-axis project inquiries are welcome.
Frequently Asked Questions
What gear ratios are available for the 60-80 joint module?
Four ratios are documented: 51, 81, 101, and 121. Peak torque rises from 42 N·m at ratio 51 to 66 N·m at ratios 101 and 121, while peak speed falls from 82 RPM to 32 RPM across that range.
What is the backlash of this module?
Published gear backlash is 20 arcsec for ratios 51 and 81, and 10 arcsec for ratios 101 and 121.
Does the 60-80 support EtherCAT?
The -2E-EC version is specified with CAN/EtherCAT communication and a 16/18-bit encoder resolution. The base and -B versions are specified with CAN only.
What supply voltage and current does it require?
Documented versions run from 24–48 V with a 300 W rated power, 5 A rated current, and 6.7 A maximum continuous current.
How heavy and how long is the module?
The 72.5 mm versions weigh 1.03–1.04 kg; the longer 91.5 mm -B version weighs 1.2 kg. All documented versions include an 18 mm hollow shaft.
Are full specifications available for the -B-2E-EC version?
Not in the published source material. That version is named by the manufacturer, but its parameter table is not provided, so request its datasheet before specifying it in a design.
Where can I buy the Ti5 Robotics 60-80 Lightweight Joint Module and what does it cost?
It is available through this listing on a request-for-quote basis. Because cost varies with version, gear ratio, and quantity, submit an inquiry describing your application to receive current pricing and availability.
Summary
The Ti5 Robotics 60-80 Lightweight Joint Module packages motor, reduction gearing, encoder, and drive electronics into a compact 1.03–1.2 kg actuator with four gear ratios, torque up to 66 N·m peak, backlash down to 10 arcsec, an 18 mm hollow shaft, and CAN or CAN/EtherCAT connectivity depending on version. With four joint versions covering short and extended housings and two fieldbus configurations, it offers a structured way to standardize joints across a humanoid or collaborative-arm design. For engineers comparing versions, confirming the undocumented -B-2E-EC data, or requesting a quotation, this page is the starting point.