Ti5 Robotics T170A V2 Humanoid Robot
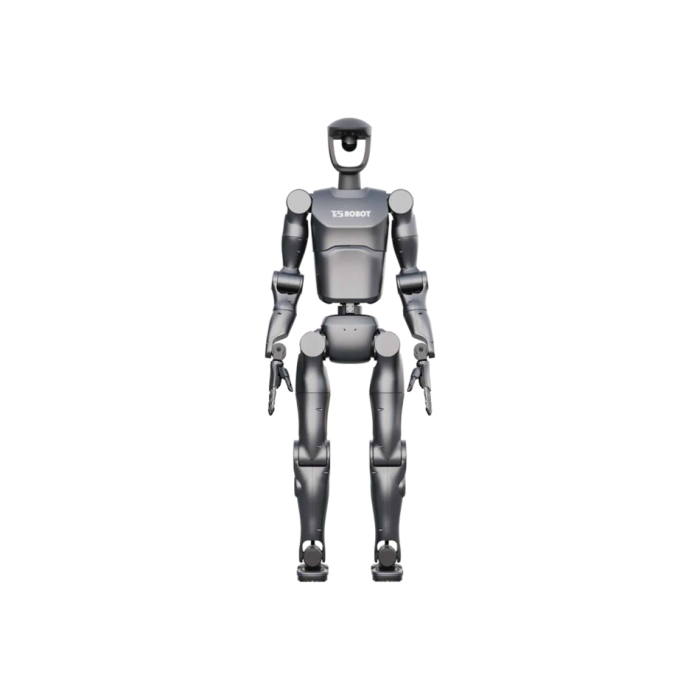
In stock
- MARCA:
- TI5 ROBOTICS
- MODELLO:
- T170A V2
- ORIGIN:
- Cina
- Warranty:
- 12 MESI
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Ti5-Robotics-T170A-V2
Ti5 Robotics T170A V2 Humanoid Robot
Ti5 Robotics T170A V2 Humanoid Robot is a full-size dual-arm humanoid platform standing 1.75 m tall, with a 1.5 m arm span and a gross weight of 58 kg. It is documented in two configurations, the Standard Model and the Flagship Model, which share the same frame, harmonic-drive joint actuation, 18-bit joint encoders, and Jetson AGX Orin 64G compute module, while differing in dexterous hands, end-of-arm force sensing, and optional obstacle-avoidance perception. The platform is aimed at research groups, system integrators, and commercial developers who need a complete humanoid with an open dual-arm software API.
Background
The T170A V2 comes from a manufacturer whose stated focus is the research, development, and manufacturing of intelligent robotic products and specialized core components for humanoid robots. That component heritage shapes the design decisions visible throughout this platform.
From joint modules to a complete humanoid
The vendor's catalog spans lightweight joint modules, intelligent bionic hands, collaborative robot arms, and humanoid robot actuators. The T170A V2 applies that actuator expertise to a complete robot: each joint uses a harmonic reducer paired with an 18-bit encoder, and the joint actuators communicate over CAN/EtherCAT interfaces. It is worth noting that although the vendor files this product under its humanoid actuator category, the published parameter table describes a complete humanoid robot with battery, sensing, and onboard computing — not a standalone motor or joint module. Buyers evaluating the listing should read the category label as a site-navigation artifact rather than a description of what is delivered.
The V2 platform and its two configurations
Both documented configurations list a total of 42 or 44 active degrees of freedom; the source presents this as a range, so the final count is configuration-dependent rather than a single fixed figure. Each arm carries a rated single-arm load of 1.5 kg with end-effector repeatability of ≤0.3 mm. The Flagship Model adds a high-precision dexterous hand (6 active degrees of freedom per hand), dual six-dimensional force sensors at the arm ends, and an optional obstacle-avoidance perception package. The Standard Model omits these items while retaining the same structure, battery, attitude sensor, and Intel RealSense D435i depth camera.
Technical Specifications
The following tables preserve the published configuration distinctions. Blank, malformed, or ambiguous source values are not confirmation of a capability; confirm the selected configuration during quotation.
Ti5 Robotics T170A V2 Humanoid Robot
| Model | T170A V2 Standard Model | T170A V2 Flagship Model |
| Total height | 1.75m | 1.75m |
| gross weight | 58kg | 58kg |
| Arm span | 1.5m | 1.5m |
| Total number of active degrees of freedom | 42 or 44 | 42 or 44 |
| Single-arm load | 1.5kg | 1.5kg |
| End-effector repeatability | ≤0.3mm | ≤0.3mm |
| Dexterous hands | / | High-precision dexterity hand |
| Dexterous hand active degrees of freedom | 6 | 6 |
| Joint actuator type | CAN/EtherCAT | CAN/EtherCAT |
| Joint reducer type | harmonic | harmonic |
| Joint encoder resolution | 18bit | 18bit |
| Battery capacity and voltage | 48V 10Ah | 48V 10Ah |
| Dual-arm end sensor | / | Six-dimensional force * 2 |
| Attitude sensor | High-precision attitude sensor | High-precision attitude sensor |
| Visual perception | Depth camera Intel RealSense D435i | Depth camera Intel RealSense D435i |
| Obstacle avoidance perception (optional) | / | have |
| Communication Protocol | Joint CANIEC, Hand 485ICAN | Joint CANIEC, Hand 485ICAN |
| Kòngzhì hé suàn lì 36 Control and computing power | Jeston AGXOrin 64G Developer Kit | Jeston AGXOrin 64G Developer Kit |
| Material | Structure: Aluminum alloy; Shell: Aluminum alloy, ABS | Structure: Aluminum alloy; Shell: Aluminum alloy, ABS |
| Software Algorithm | double arms API | double arms API |
How does the Standard Model differ from the Flagship Model?
The two configurations are mechanically and computationally identical in the published table: same height, weight, arm span, payload, repeatability, joints, battery, and Jetson AGX Orin compute. The differences are concentrated at the end effectors and perception layer. The Flagship Model ships with a high-precision dexterous hand, a pair of six-dimensional force sensors at the arm ends for force-aware manipulation, and the option of an obstacle-avoidance perception package. The Standard Model is the leaner entry point for teams that plan to fit their own end effectors or do not require force sensing. Because the 42-or-44 degree-of-freedom figure is configuration-dependent, buyers should confirm the exact joint count for their chosen build at the quotation stage.
Who is the Ti5 Robotics T170A V2 for?
The T170A V2 suits robotics research laboratories, university programs, and corporate R&D teams working on humanoid locomotion, dual-arm manipulation, and embodied AI. Its CAN/EtherCAT joint architecture and dual-arm API make it relevant to integrators who want a documented interface layer rather than a closed appliance. The Flagship configuration, with force sensing and a dexterous hand, is oriented toward teams doing contact-rich manipulation research, while the Standard configuration serves groups prioritizing a lower-complexity base platform.
What is the Ti5 Robotics T170A V2 used for?
- Scientific research and education, including coursework and experiments in humanoid kinematics, dynamics, and whole-body control.
- Dual-arm manipulation development using the vendor's dual-arm API and the platform's ≤0.3 mm end-effector repeatability.
- Industrial production research, such as prototyping handling and tending tasks within the 1.5 kg single-arm load rating.
- Perception and navigation research built on the Intel RealSense D435i depth camera and, on the Flagship Model, the optional obstacle-avoidance package.
- Force-controlled interaction studies using the Flagship Model's dual six-dimensional end-of-arm force sensors.
- Commercial scenario prototyping and investigation work in vendor-listed application areas such as commercial venues and medical or rehabilitation research environments.
Pricing and Availability
The T170A V2 is quoted on a per-configuration basis. Final pricing depends on the selected model (Standard or Flagship), the degree-of-freedom configuration, and optional items such as the obstacle-avoidance perception package. To receive current pricing, lead time, and configuration guidance, submit a quote request through this listing with a brief description of your intended application; a specialist can then confirm the appropriate build and any documentation requirements for your region.
Frequently Asked Questions
How many degrees of freedom does the T170A V2 have?
The source lists 42 or 44 total active degrees of freedom for both models; the final count depends on the chosen configuration. Each dexterous hand adds 6 active degrees of freedom where fitted.
What is the difference between the Standard and Flagship configurations?
The Flagship adds a high-precision dexterous hand, two six-dimensional end-of-arm force sensors, and an optional obstacle-avoidance perception package. All other published parameters are identical between the two.
What sensors are included?
Both models carry a high-precision attitude sensor and an Intel RealSense D435i depth camera. Six-dimensional force sensors and obstacle-avoidance perception are Flagship-only, with obstacle avoidance listed as optional.
How is the robot controlled and programmed?
Onboard computing is a Jetson AGX Orin 64G Developer Kit, joints use CAN/EtherCAT actuator interfaces with harmonic reducers and 18-bit encoders, and the vendor provides a dual-arm API for development.
What are the payload and precision figures?
Each arm is rated for a 1.5 kg single-arm load with end-effector repeatability of ≤0.3 mm, consistent across both configurations.
What power system does it use?
Both configurations list a 48 V, 10 Ah battery. The source does not publish runtime figures, so operating duration should be confirmed for your duty cycle at the quotation stage.
Where can I buy the Ti5 Robotics T170A V2 Humanoid Robot and what does it cost?
It is available through this listing on a request-for-quote basis. Because pricing varies with configuration and options, submit an inquiry describing your application to receive a formal quotation and delivery estimate.
Summary
The Ti5 Robotics T170A V2 is a 1.75 m, 58 kg dual-arm humanoid built on the vendor's own harmonic-drive actuator technology, offered in Standard and Flagship configurations that differ in hands, force sensing, and obstacle-avoidance options. With CAN/EtherCAT joints, 18-bit encoders, Jetson AGX Orin computing, and a dual-arm API, it is positioned as a development-ready platform for research, education, and integration work. For configuration advice and a formal quotation, this page is the starting point.