Ti5 Robotics EBLM A Series Collaborative Robot Arms
In stock
- MARKA:
- TI5 ROBOTICS
- MODELKA:
- EBLM-A-Series
- ORIGIN:
- Chiny
- Warranty:
- 12 MIESIĘCY
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Ti5-Robotics-EBLM-A-Series
Ti5 Robotics EBLM A Series Collaborative Robot Arms
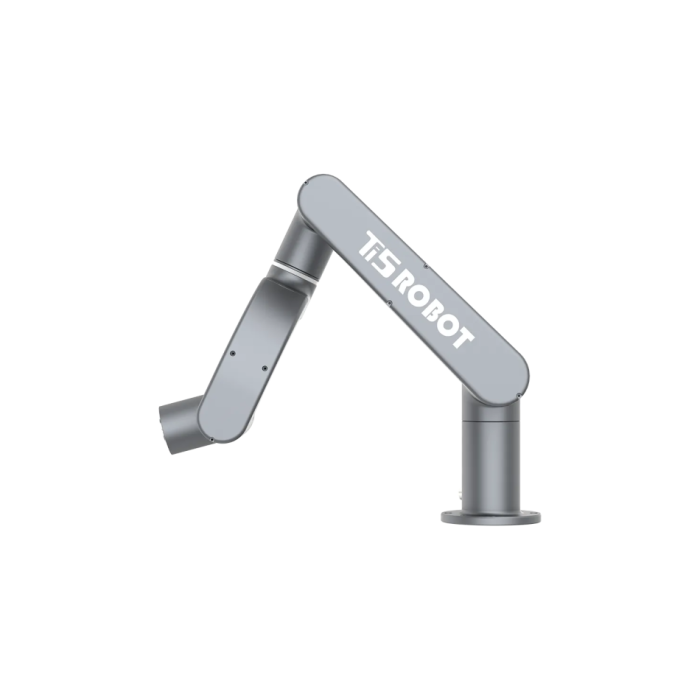
Ti5 Robotics EBLM A Series Collaborative Robot Arms are compact six-axis cobot arms built by Ti5 Robotics for light-payload automation, research, and development work. The family documented on the manufacturer's page comprises two variants, the EBLM-1.5A and the EBLM-2A, which share a common aluminum-alloy construction and open software interfaces while differing in payload, reach, mass, and motion performance. This page covers the EBLM A Series as a single product family; both documented variants are described below so buyers can compare them directly before requesting a configuration.
Background
Ti5 Robotics and the EBLM platform
Ti5 Robotics positions itself as a developer of high-performance, industry-standard robot products, with a stated aim of lowering the threshold for customers to develop and use robots and thereby restructuring the robot and industrial-automation supply chain. The company's wider portfolio includes lightweight joint modules, intelligent bionic hands, humanoid robot actuators, and collaborative robot arms; the EBLM A Series sits in the collaborative-arm line and draws on the same joint-module engineering used across the catalog. The arms are presented by the manufacturer as ready-for-integration products aimed at industrial production, scientific research and education, commercial scenarios, and related integration projects.
Design approach of the A Series
Both A Series variants are six-degree-of-freedom arms with an aluminum-alloy body finished in a Space Gray exterior style. Joint ranges of motion are identical across the two models, with ±180° travel on most axes and ±150° on J3, which simplifies porting motion programs between variants. Communication with the arm body is available over CAN or EtherCAT, and the manufacturer lists ROS, Python, and C++ interfaces, reflecting an openness-first design intended for developers as much as for end users. Each arm ships with a standard one-metre cable and accepts a 28–48 VDC supply. The practical difference between the variants lies in scale: the EBLM-1.5A is the lighter, shorter-reach, faster-tool-speed option, while the EBLM-2A trades some speed for higher payload and a longer working radius.
Technical Specifications
The following tables preserve the published configuration distinctions. Blank, malformed, or ambiguous source values are not confirmation of a capability; confirm the selected configuration during quotation.
Ti5 Robot Eblm-1.5A
| Name | Unit | Ti5 Robot Eblm-1.5A |
| Rated load | kg | 1.5 |
| weight | kg | 4.9 |
| Working radius | mm | 460 |
| Repeatability | mm | ±0.5 |
| Degrees of freedom | - | 6 |
| Body material | - | aluminum alloy |
| Exterior Style | - | Space Gray |
| Joint range of motion | 。 | J1(±180) J2(±180) J3(±150) J4(±180) J5(±180) J6(±180) |
| Joint speed | °/s | J1(±280) J2(±180) J3(±180) J4(±220) J5(±220) J6(±220) |
| Typical speed on the tool side | m/s | 2 |
| Ontology communication | - | Can/EtherCat |
| Temperature range | Not clearly specified in source | |
| IP Level | - | IP50 |
| Power supply voltage range | - | 28-48VDC |
| Rated power | W | 65 |
| Maximum power | W | 90 |
| Standard cable length | m | 1 |
| Interfaces and Openness | - | ROS、Python、C++ |
Ti5 Robot Eblm-2A
| Name | Unit | Ti5 Robot Eblm-2A |
| Rated load | kg | 2 |
| weight | kg | 5.8 |
| Working radius | mm | 550 |
| Repeatability | mm | ±0.5 |
| Degrees of freedom | - | 6 |
| Body material | - | aluminum alloy |
| Exterior Style | - | Space Gray |
| Joint range of motion | 。 | J1(±180) J2(±180) J3(±150) J4(±180) J5(±180) J6(±180) |
| Joint speed | °/s | J1(±180) J2(±180) J3(±180) J4(±220) J5(±220) J6(±220) |
| Typical speed on the tool side | m/s | 1 |
| Ontology communication | - | Can/EtherCat |
| Temperature range | Not clearly specified in source | |
| IP Level | - | IP50 |
| Power supply voltage range | - | 28-48VDC |
| Rated power | W | 85 |
| Maximum power | W | 110 |
| Standard cable length | m | 1 |
| Interfaces and Openness | - | ROS、Python、C++ |
How do the EBLM-1.5A and EBLM-2A differ in practice?
Choosing between the two variants comes down to the workpiece and the cell layout. The EBLM-1.5A handles payloads up to 1.5 kg within a 460 mm working radius and reaches a typical tool-side speed of 2 m/s, with a faster J1 base joint at ±280°/s, making it suited to quick, small-envelope pick-and-place or lab manipulation. The EBLM-2A extends the rated load to 2 kg and the reach to 550 mm, at a typical tool-side speed of 1 m/s and slightly higher power draw. Repeatability, joint travel, communication options, and software interfaces are the same on both, so the decision rarely affects the control-software side of an integration.
Who is the Ti5 Robotics EBLM A Series for?
The series targets integrators, research groups, and product developers who need a light, open, developer-friendly cobot arm rather than a heavy industrial manipulator. University and vocational robotics programs benefit from the ROS, Python, and C++ interfaces for teaching and experimentation. Automation integrators can use the arms for light assembly, inspection assistance, and machine-tending tasks within the stated payload limits. Developers of larger robotic systems, including mobile platforms, may also evaluate the arms as manipulator subsystems, given their low body mass of roughly five to six kilograms.
What is the Ti5 Robotics EBLM A Series used for?
- Light pick-and-place and part-handling tasks involving workpieces within the 1.5 kg or 2 kg rated loads.
- Scientific research and education, where open ROS, Python, and C++ interfaces support coursework and experimentation.
- Prototyping and development of automation cells before scaling to larger production equipment.
- Light assembly and fastening assistance in commercial and industrial settings within the arms' reach and payload envelope.
- Camera- or sensor-carrying positioning tasks such as inspection support, using the ±0.5 mm repeatability.
- Integration onto mobile robots or custom machines as a compact manipulator subsystem, aided by the low arm weight and 28–48 VDC supply range.
Pricing and Availability
Pricing for the EBLM A Series depends on the selected variant, requested configuration, and any accompanying accessories or integration support, so it is provided on a quotation basis rather than as a fixed list price. To obtain current pricing and lead-time information, submit a quote request through this listing with the intended variant (EBLM-1.5A or EBLM-2A), your application outline, and any interface requirements. A sales engineer can then confirm availability and recommend the appropriate configuration.
Frequently Asked Questions
How many variants are in the EBLM A Series?
The manufacturer documents two variants on this product page: the EBLM-1.5A with a 1.5 kg rated load and 460 mm working radius, and the EBLM-2A with a 2 kg rated load and 550 mm working radius.
What software can I use to control the arms?
Both variants list ROS, Python, and C++ interfaces, with body communication over CAN or EtherCAT, allowing integration into common robotics development environments.
What power supply do the arms require?
Both variants accept a 28–48 VDC supply. Rated power is 65 W for the EBLM-1.5A and 85 W for the EBLM-2A, with maximum power of 90 W and 110 W respectively.
How precise are the EBLM A Series arms?
Both variants are specified at ±0.5 mm repeatability, which is adequate for light handling, inspection support, and many research and education tasks.
Are the arms suitable for harsh or wet environments?
The published ingress protection rating is IP50, which indicates protection against dust ingress but not against liquids. The temperature specification in the source documentation is incomplete, so environmental limits should be confirmed with the vendor for any demanding installation.
Can the EBLM A Series be mounted on mobile robots?
The low arm mass (4.9 kg and 5.8 kg) and DC supply range make the series a candidate for mobile integration, but suitability depends on your platform's payload, power budget, and control architecture; discuss the use case when requesting a quote.
Where can I buy the Ti5 Robotics EBLM A Series and what does it cost?
The series is available through this listing on a quotation basis. Submit a quote request specifying the EBLM-1.5A or EBLM-2A and your application details, and you will receive current pricing, configuration guidance, and availability information.
Summary
The Ti5 Robotics EBLM A Series offers two compact six-axis collaborative arms — the 1.5 kg-payload EBLM-1.5A and the 2 kg-payload EBLM-2A — built on aluminum-alloy bodies with CAN/EtherCAT communication and open ROS, Python, and C++ interfaces. With sub-millimetre repeatability and arm weights under six kilograms, they suit research, education, light automation, and manipulator integration projects. For specification review, variant selection, and a formal quotation, this page is the starting point.